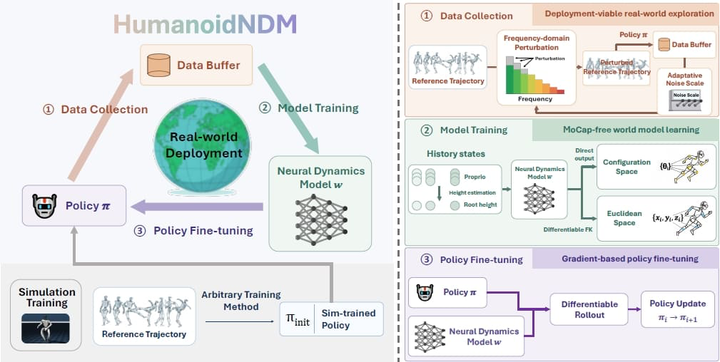
HumanoidNDM: Closing the Training-Deployment Gap of Motion Tracking via Humanoid Neural Dynamics Model
Coming Soon
Type
Publication
In Conference on Robot Learning (CoRL 2026)

Yusen Feng
Fifth-year Ph.D. Student
I’m a fifth-year Ph.D. student at Peking University advised by Libin Liu.